Reference locations

Real projects. Proven solutions.

DriveByCloud’s published references span a proving ground, a motorway section, and a smart-road programme in Hungary. We build solutions that work and help our partners succeed.
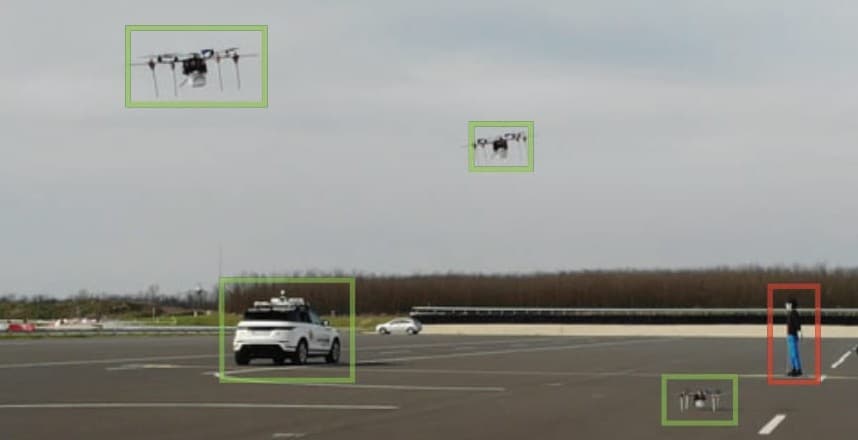
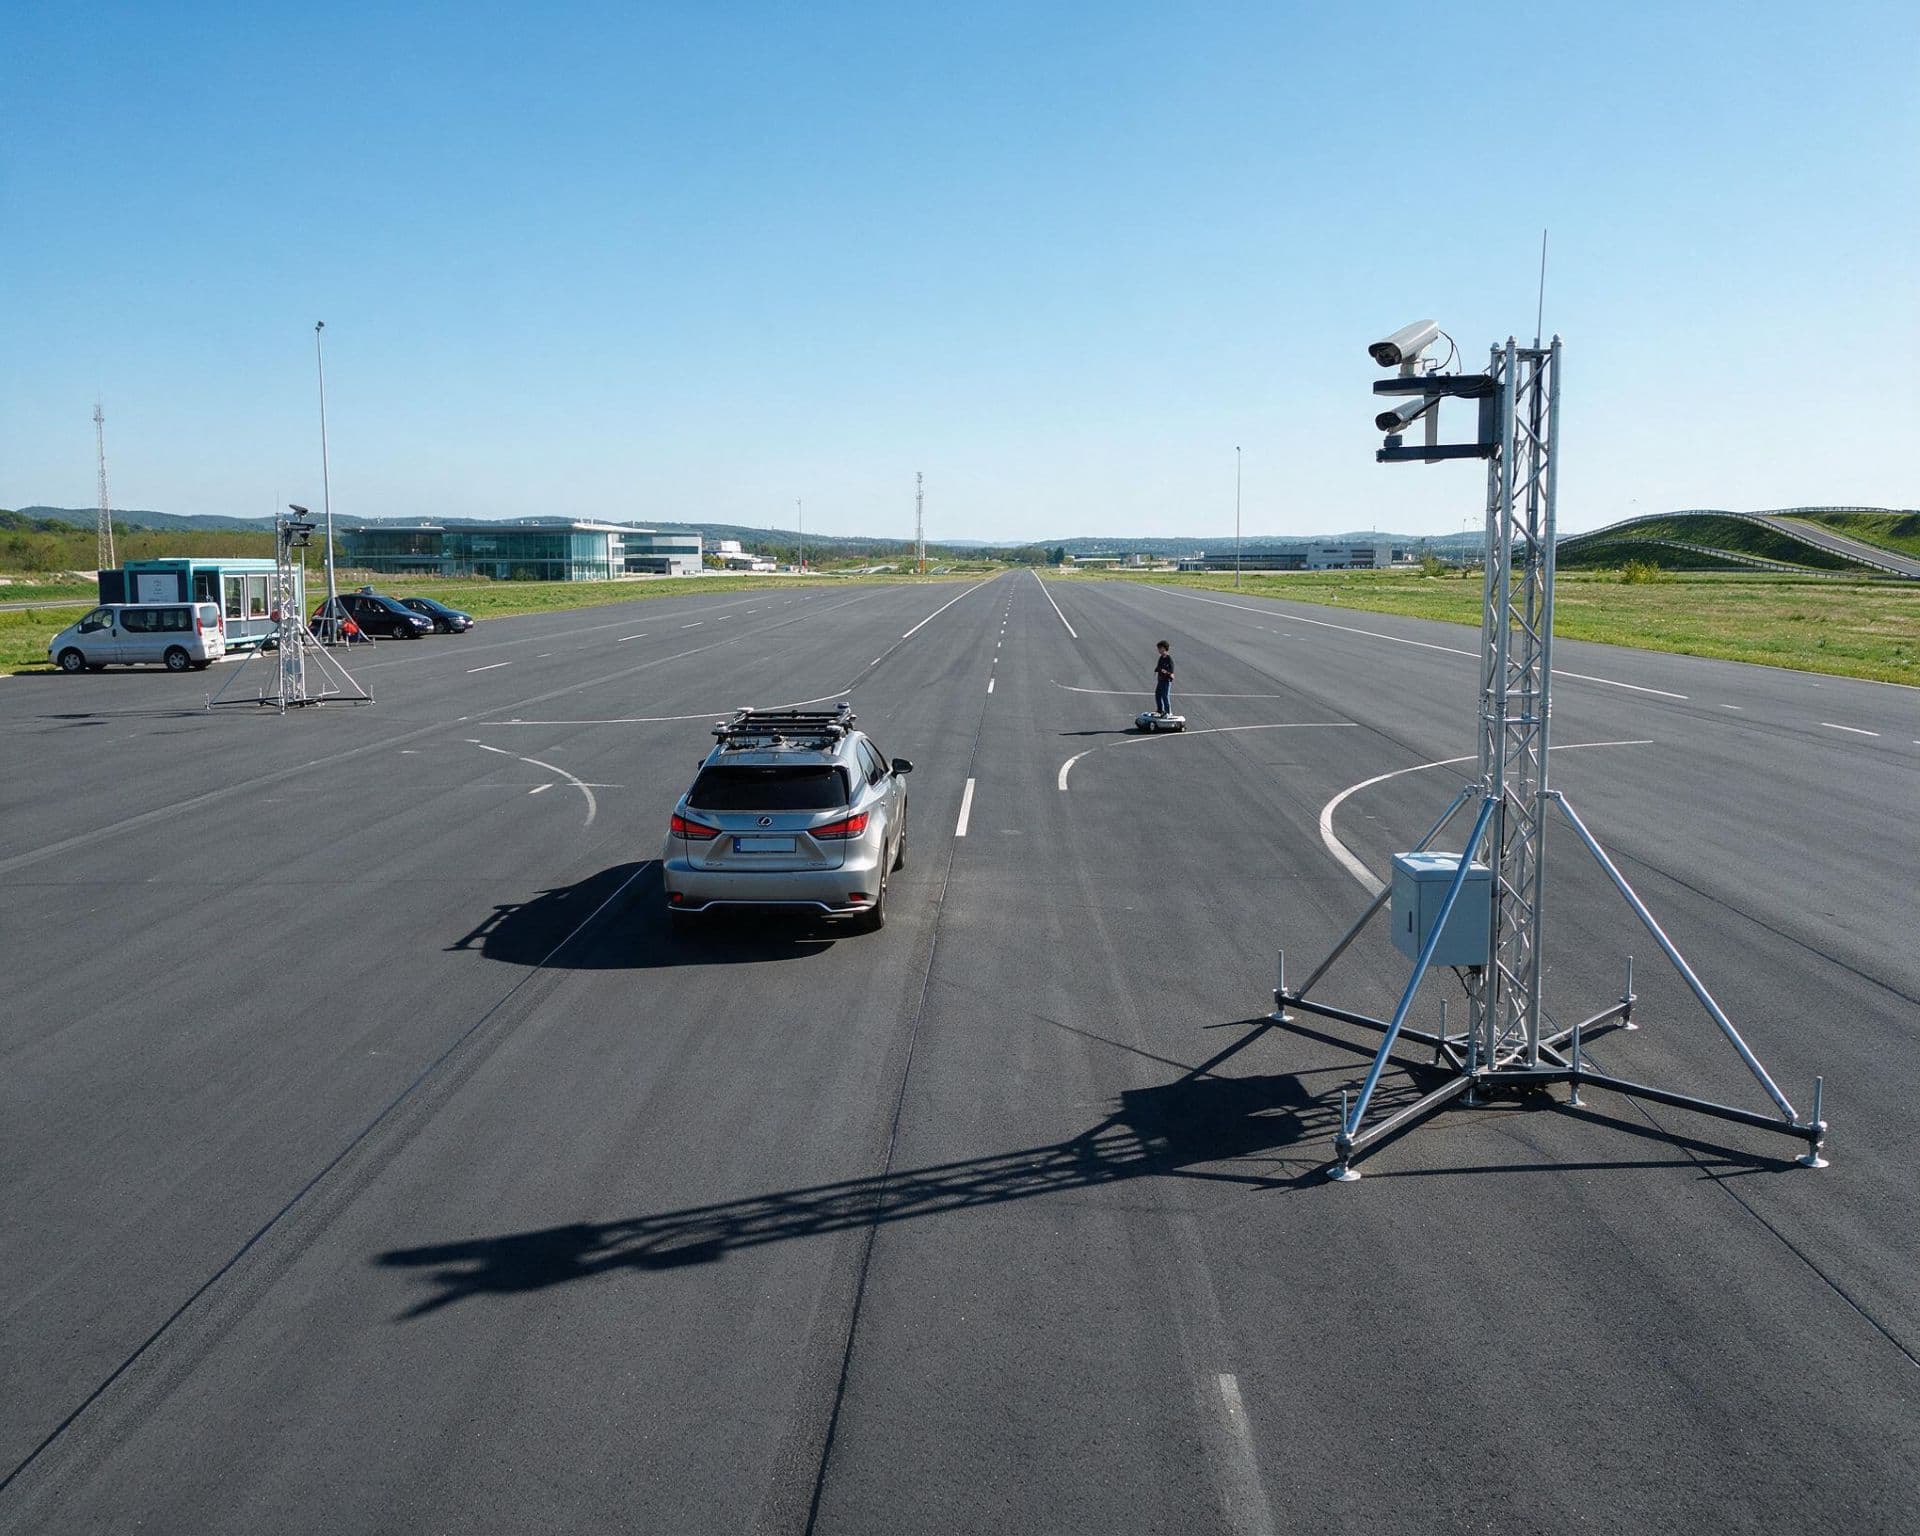
Proving-ground test with a vehicle, pedestrians and drones, each detected and marked with a bounding box
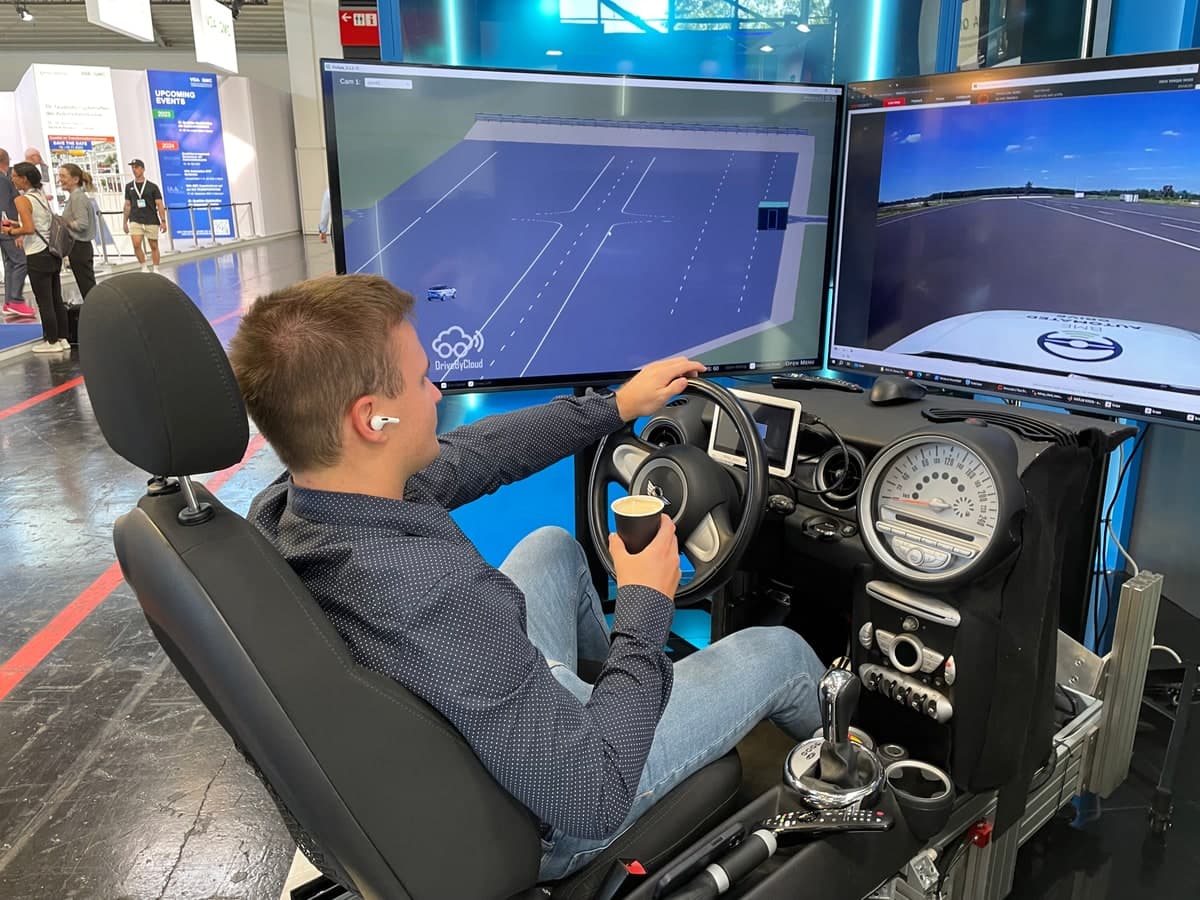
A driver using the teleoperation demonstrator with digital-twin and vehicle-camera displays
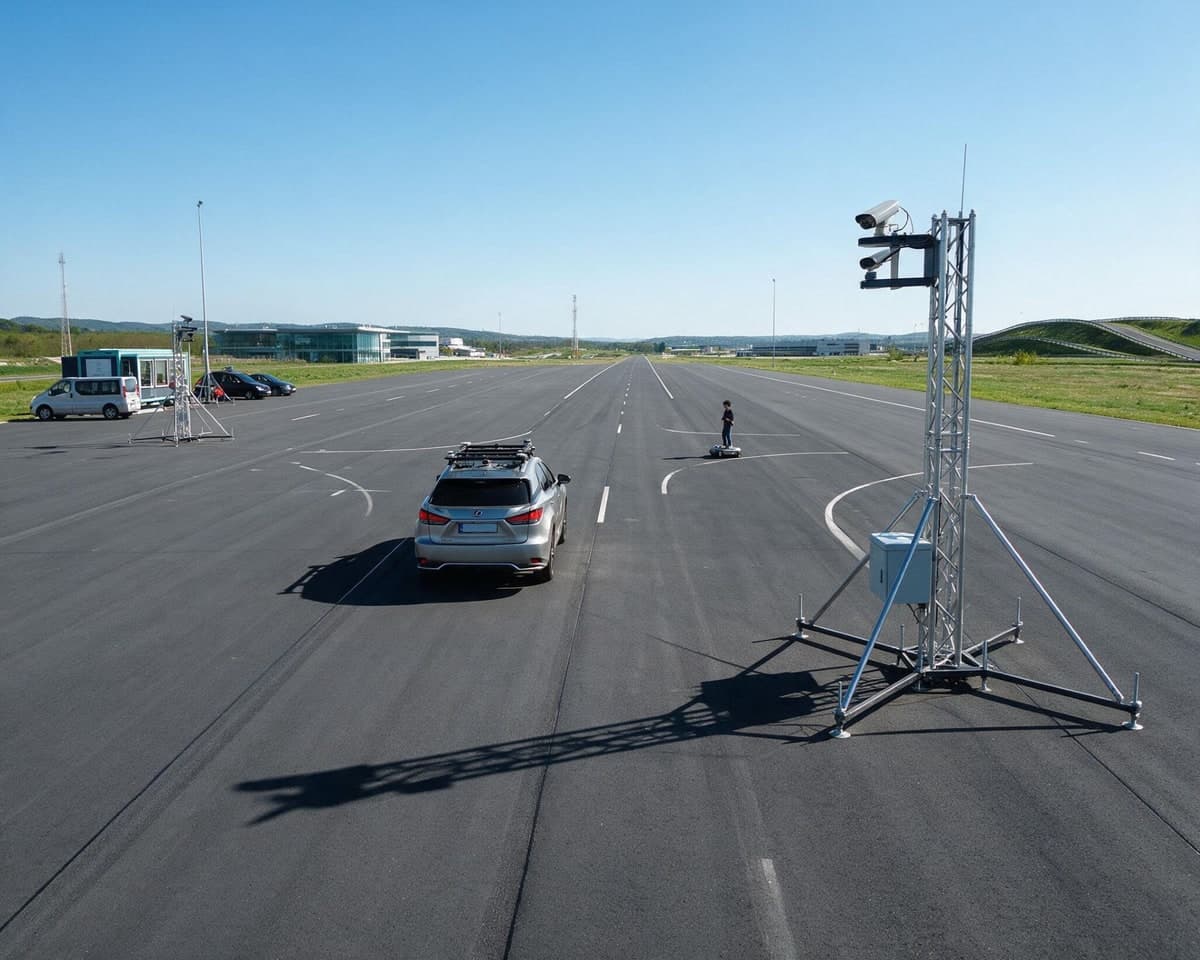
A test vehicle and roadside camera stations on a proving-ground measurement area
Scope, evidence and deliverables

From an engineering problem to reviewable evidence

See what each demonstration or workflow establishes, and what a deployment or pilot needs to define. Research evidence and commercially agreed deliverables have distinct scopes.

Workflows 1–3 of 4

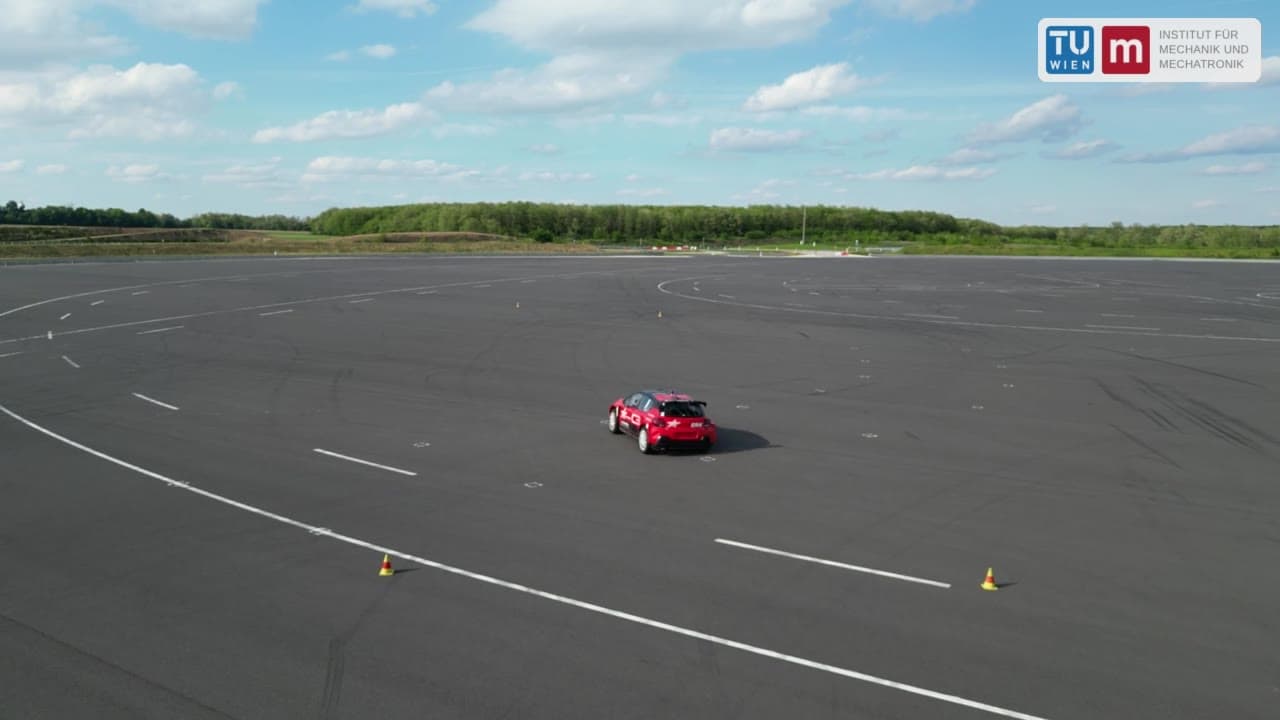
CloudControl proving-ground demonstration of cloud-guided vehicle motion
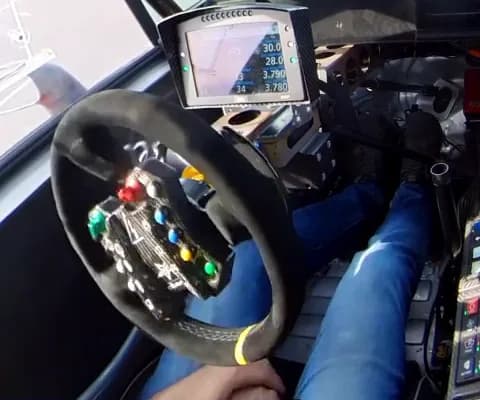
Cockpit view during a cloud-controlled run: the steering wheel is turned while the driver's hands rest in the lap
Hands off

Recorded control demonstrations

CloudControl: cloud-based and remote vehicle control

Use the shared test-area scene for cloud-planned vehicle motion or Teleoperation by a remote operator.

Recordings show cloud-guided path following, obstacle replanning and mixed-reality tests, alongside transcontinental remote driving through Teleoperation.

  • Cloud-based trajectory planning
  • Remote Teleoperation
  • Mixed-reality scenarios
Technical scope & evidence
System
CloudControl uses infrastructure perception and TwinStreamer Engine for cloud-based trajectory planning, vehicle path following and its Teleoperation capability.
Project deliverables
A scoped pilot defines the operating area, perception inputs, planning and vehicle interfaces, safety constraints and timing measurements before execution.
Evidence
Watch the CloudControl project highlights for the demonstrated path-following and replanning workflows. Latency and operating limits are measured for each deployment.
Vehicle measurement setup used to illustrate the ADAS engineering context

Repeatable ADAS scenario test execution

Available summer 2027

A repeatable ADAS test workflow

Execute an agreed test procedure consistently and keep the evidence needed to evaluate each run.

The workflow illustration explains how a run moves from a defined procedure to a reviewable pass/fail report. It is not a published performance benchmark.

  • Procedure → execution → report
  • Project-defined acceptance criteria
  • Traceable run evidence
Technical scope & evidence
System
ScenX structures procedure steps, execution, reference measurements and acceptance checks into one workflow.
Project deliverables
A scoped pilot defines the procedure, coordinate calibration, interfaces, acceptance thresholds and report format before the test is run.
Evidence
Two reports generated by ScenX from an AEB test with a child dummy standing in the lane: one 30 km/h run, and a summary of 20 runs at 10 and 30 km/h with measured distances between the vehicle and 13 points on the dummy. They show the report format, not customer results; a technical discussion establishes the evidence required for your test.
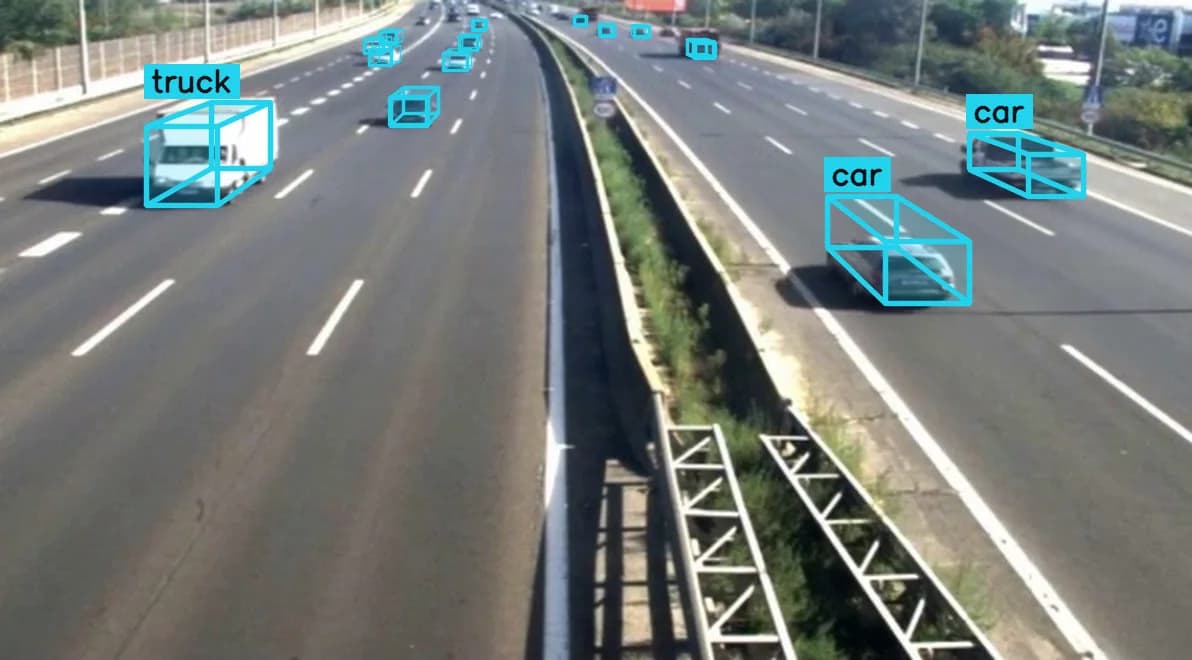
Roadside camera view of M1–M7 traffic with vehicle detections

Recorded motorway demonstration

Roadside perception on the M1–M7 highway

Collect and evaluate large scale microscopic traffic data online.

We map the entire 1.5 km shared motorway section into the digital twin with low latency: every tracked vehicle appears in the digital road scene within 100 ms.

  • 1.5 km motorway corridor
  • Camera + thermal + LiDAR
  • Referenced vehicle tracks
Technical scope & evidence
System
Camera, thermal camera and LiDAR perception at roadside stations feed a shared 3D motorway model through TwinStreamer Engine.
Project deliverables
A project can combine referenced object streams, recording playback and an agreed data export. Coverage, object taxonomy and output interfaces are defined during scoping.
Evidence
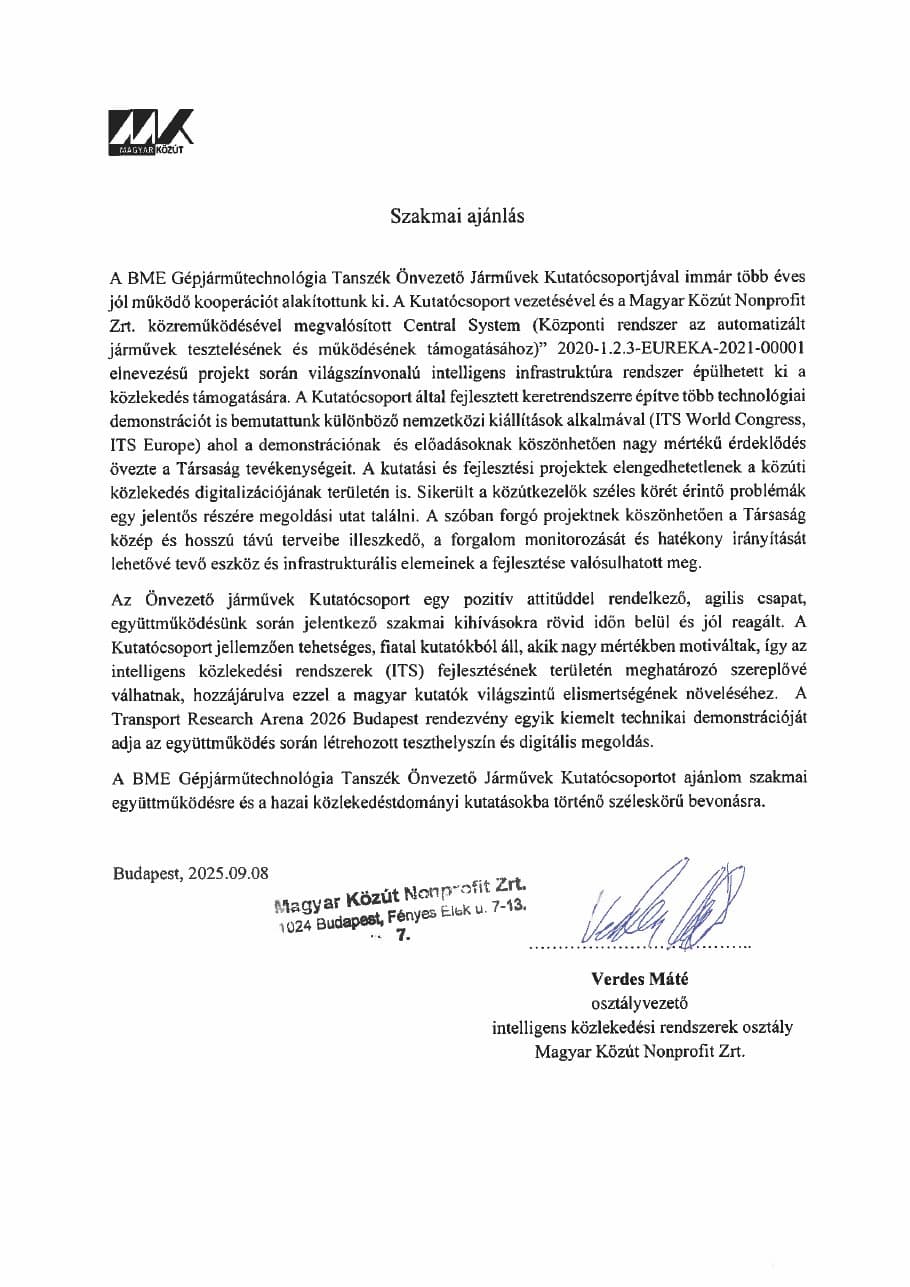
Review the paired camera/digital-twin recording and the road operator’s signed recommendation to the DriveByCloud research group.
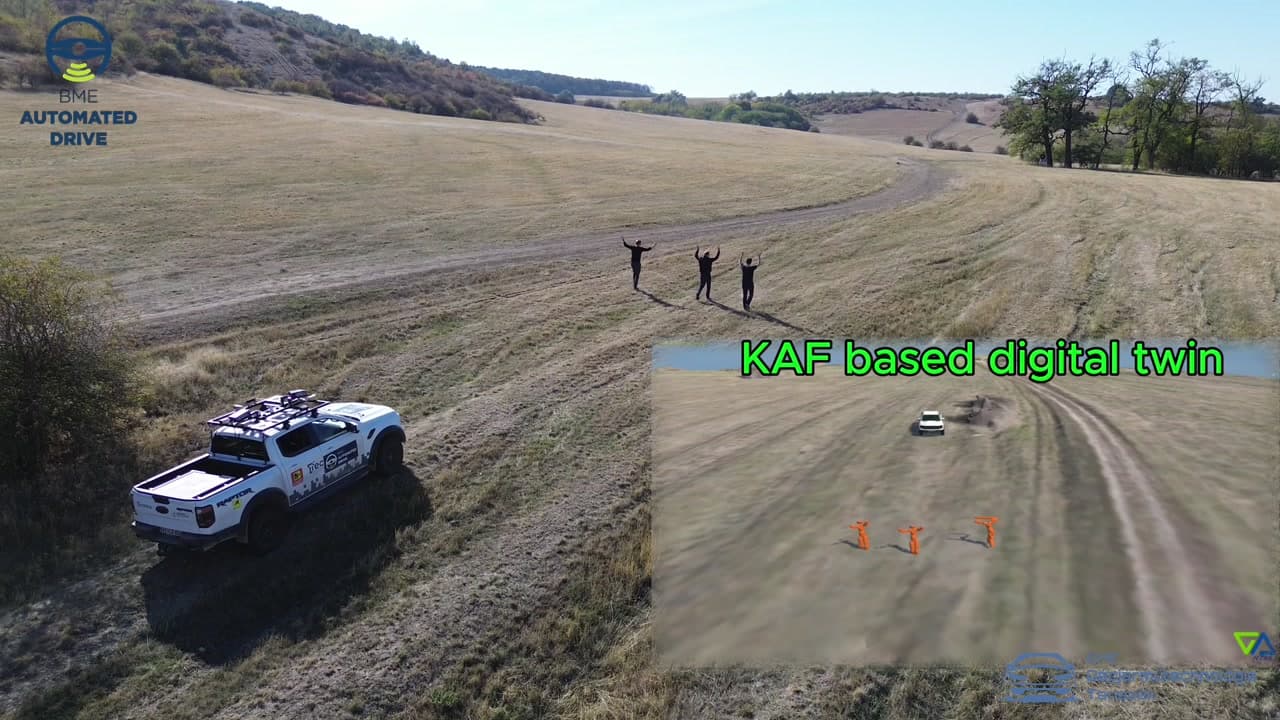
Field Monitoring project demonstrating cooperative aerial and ground observation

Recorded UAV–UGV demonstration

Cooperative monitoring of a protected area

Maintain a shared view of a site and investigate areas that a single observer cannot see.

The demonstration shows blind-spot reconnaissance, cooperative visual localization and coordinated drone/ground-vehicle operation.

  • Cooperative aerial + ground observation
  • Blind-spot reconnaissance
  • Digital-twin coordination
Technical scope & evidence
System
Aerial and ground observations are brought into the Central Autonomy Cloud digital twin to coordinate monitoring and vehicle actions.
Project deliverables
A site-monitoring project defines the observation area, object/event outputs, operating constraints and intervention interfaces. Deployment-specific response times require measurement.
Evidence
Watch the Field Monitoring project recording for the demonstrated observation, decision and intervention sequence.
Technology in action

Our Projects

Explore cloud-guided driving, the M1–M7 motorway digital twin, transcontinental teleoperation, cooperative area protection, and high-speed cloud control through recorded project demonstrations.

CloudControl

From the digital twin to vehicle motion

A short look at cloud-guided driving: a real vehicle on the test area, path following in the shared scene, and trajectories replanned around physical and virtual road users. The tests were driven at 90 km/h, made possible by the efficient TwinStreamer Engine, which keeps the digital twin in sync with ultra-low latency.

  • Tested at 90 km/h
  • Ultra-low-latency TwinStreamer Engine
  • Cloud-based trajectory planning
  • Physical-obstacle replanning
  • Mixed-reality pedestrian tests
Discuss this project
CloudControl project highlights: proving-ground driving, cloud-based path following, trajectory replanning around a pedestrian dummy, and a mixed-reality pedestrian scenario.

CloudControl, project 1 of 5

Partner recommendations

Recommended by industry and road-operator partners

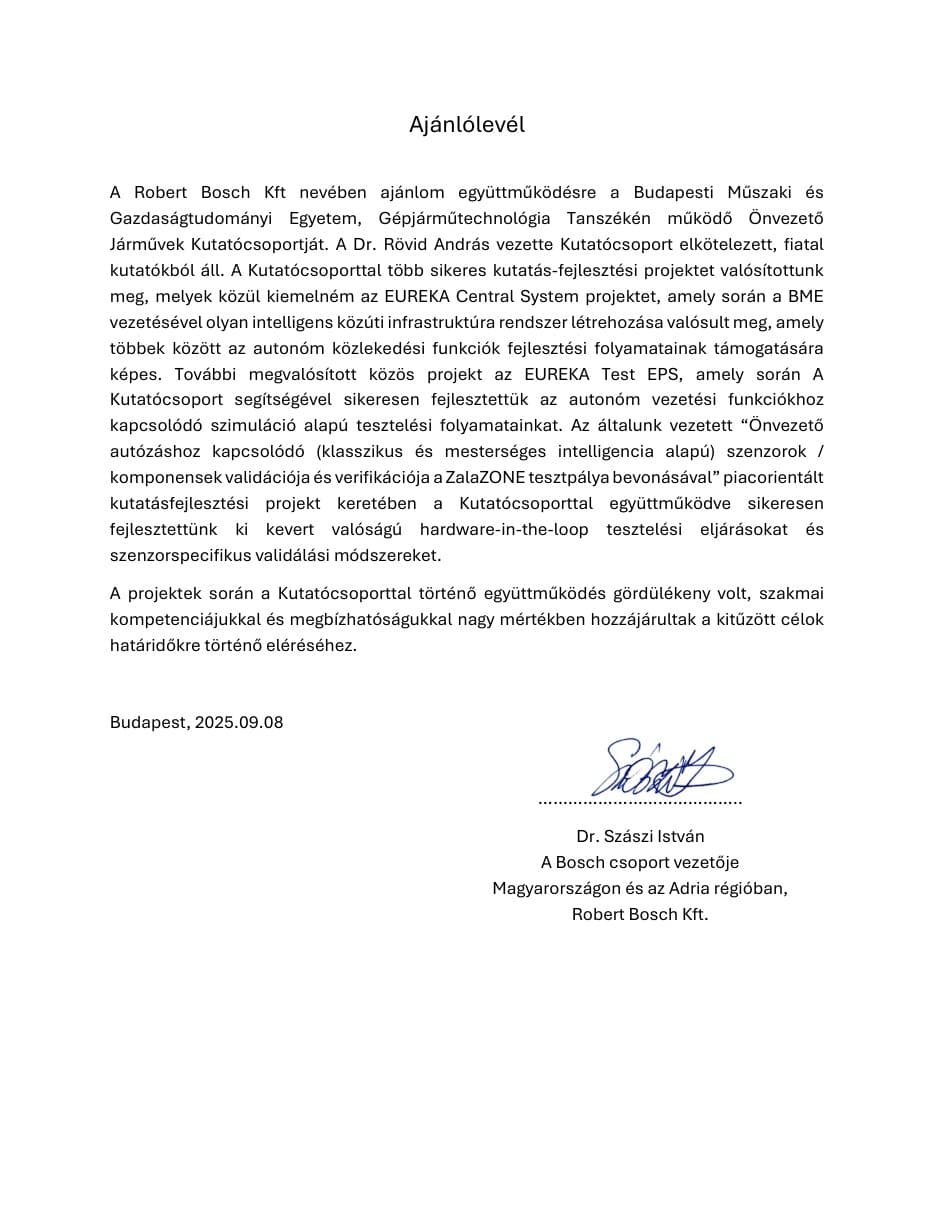
Signed recommendation letters for the DriveByCloud research group led by Dr. András Rövid, whose founders and researchers build DriveByCloud’s technology.

Dr. István Szászi

Head of the Bosch Group in Hungary and the Adriatic region

Robert Bosch Kft.

“Cooperation with the research group was smooth; their professional competence and reliability contributed greatly to reaching the project goals on schedule.”

Bosch recommends the research group for cooperation after several joint R&D projects, highlighting the BME-led EUREKA Central System project, which created an intelligent road-infrastructure system that supports the development of automated-driving functions.

  • EUREKA Central System: intelligent road infrastructure under BME leadership
  • EUREKA testEPS: simulation-based testing of automated-driving functions
  • ZalaZONE sensor validation: mixed-reality hardware-in-the-loop test methods
Signed recommendation letter from Dr. István Szászi, Robert Bosch Kft., dated 8 September 2025Open the signed letter (PDF, Hungarian) (opens in a new tab)

Budapest, 8 September 2025

Máté Verdes

Head of the Intelligent Transport Systems Department

Hungarian Public Roads

“A world-class intelligent infrastructure system was built to support transport. The test site and digital solution created during our cooperation are one of the highlighted technical demonstrations of Transport Research Arena 2026 Budapest.”

Hungary’s national road operator describes a multi-year cooperation and recommends the research group for professional collaboration and broad involvement in Hungarian transport research.

  • Central System project (2020-1.2.3-EUREKA-2021-00001) with Hungarian Public Roads
  • Technology demonstrations at ITS World Congress and ITS European Congress
  • Highlighted technical demonstration at TRA 2026 Budapest
Signed recommendation letter from Máté Verdes, Hungarian Public Roads, dated 8 September 2025Open the signed letter (PDF, Hungarian) (opens in a new tab)

Budapest, 8 September 2025

Plan a project

Discuss your test environment

Tell us about the road, proving ground, interfaces, and evidence your team needs to connect.